Program
Venues
- All presentations will be held in Esther Simpson Lecture Theatre (LG.08)
- Posters and exhibitors, refreshment breaks, and the reception will be held in the Newlyn Building Seminar Rooms
- Lunch will be served in the Refectory
Find below the program for CRAS 2026 in Leeds. We look forward to seeing you all there!
| Time | Wednesday September 16 |
Thursday September 17 |
Friday September 18 |
|---|---|---|---|
| 8:30 | |||
| 9:00 |
Oral Presentations 3 (Human Factors and Surgical Performance) |
Oral Presentations 6** (Novel Devices) |
|
| 9:30 | |||
| 10:00 |
Poster Pitches 1 Guest Speaker: Prof Hongliang Ren |
Poster Pitches 2 | |
| 10:30 | |||
| 11:00 |
Coffee Break (Poster Session 1*) |
Coffee Break (Poster Session 2*) |
|
| 11:30 | |||
| 12:00 |
Registration (12:00 - 13:45) |
Keynote 3 Prof Bradley Nelson |
Keynote 5 Prof Christian Duriez |
| 12:30 | |||
| 13:00 | Lunch Break | Lunch Break | |
| 13:30 |
Opening Ceremony (13:45 - 14:00) |
||
| 14:00 |
Keynote 1 Prof Stefanie Speidel |
||
| 14:30 |
Keynote 4 Prof Dan Stoyanov |
Keynote 6 Prof David Jayne |
|
| 15:00 |
Oral Presentations 1 (Imaging and Visualisation) |
||
| 15:30 |
Oral Presentations 4 (Sensing and Control 1) |
Coffee Break | |
| 16:00 | Coffee Break |
Oral Presentations 7 (Sensing and Control 2) |
|
| 16:30 |
Keynote 2 Dr Massimiliano Simi |
Coffee Break | |
| 17:00 |
Oral Presentations 5 (Magnetics) |
Awards & Closing Ceremony | |
| 17:30 |
Oral Presentations 2 (Surgical Robots & Autonomy) |
||
| 18:00 | |||
| 18:30 | Welcome Reception | ||
| 19:00 | |||
| 19:30 |
Conference Dinner (supported by Kuka Deutschland GmbH) |
||
| 20:00 | |||
| 20:30 | |||
| 21:00 | |||
| 21:30 | |||
| 22:00 | |||
| 22:30 |
*All posters are to be displayed for the full conference
**Oral Session 6 will finish at 10:10
Presentation Times
Presenters, please find information on your presentation slots belowKeynote Talks
Beyond the Scalpel: From Intelligent Assistance to Autonomous Surgery | |
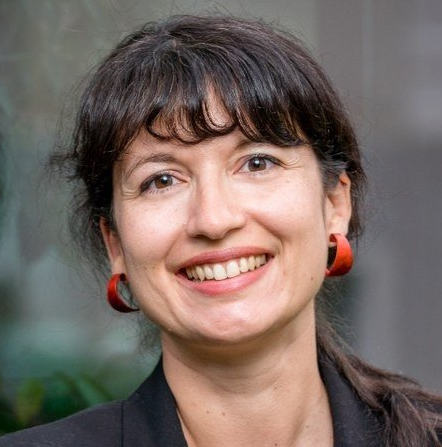 Prof. Stefanie SpeidelProfessor in Translational Oncology, National Center for Tumor Diseases Dresden |
Stefanie Speidel has been Professor of Translational Surgical Oncology and a director at the National Center for Tumor Diseases Dresden since 2017. She is also one of the speakers of the DFG Cluster of Excellence CeTI and the Konrad Zuse AI School SECAI. She received her PhD from Karlsruhe Institute of Technology in 2009 and led the junior research group Computer-Assisted Surgery from 2012 to 2016. She is Board Secretary and a Fellow of the MICCAI Society. She has co-authored more than 170 publications, organises key workshops and challenges, and has served as general chair and programme chair for major international conferences, including IPCAI and MICCAI. Her research focuses on machine learning for image- and robot-assisted surgery. |
Robotic Open Microsurgery: Past, Present and Future | |
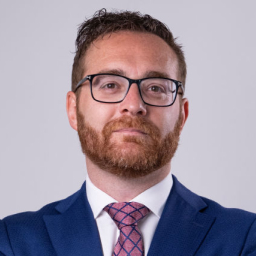 Dr Massimiliano SimiExecutive Vice President of R&D, Medical Microinstruments, Inc. |
Dr Massimiliano ‘Max’ Simi is Co-Founder and Chief Technology Officer of MMI, bringing over 15 years of leadership in surgical robotics. Driven by a passion for innovation, he invented the proprietary NanoWrist instrument, which forms the foundation of MMI’s patent portfolio. He continues to direct research and product development and upgrades for the flagship Symani Surgical System and Synaptix visualisation platform. Prior to co-founding MMI, Max served as an engineer, delivering advanced robotic and mechatronic solutions to Silicon Valley medical-device start-ups. He holds a PhD in Innovative Technologies and Medical Robotics from Scuola Superiore Sant’Anna in Pisa, an Executive MBA, and both an MSc and BSc in Biomedical Engineering from the University of Pisa. |
Clinically Ready Microrobots | |
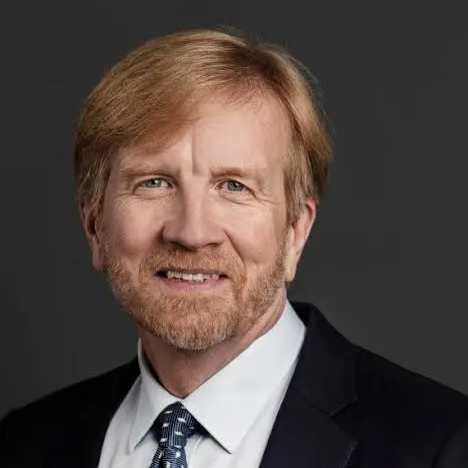 Prof. Brad NelsonProfessor of Robotics and Intelligent Systems, ETH Zürich; Co-Founder, Nanoflex Robotics and Ophthorobotics |
Brad Nelson has been Professor of Robotics and Intelligent Systems at ETH Zürich since 2002, where his research focuses on micro-, nano-, and medical robotics. He studied mechanical engineering at Illinois and Minnesota, worked in computer vision at Honeywell and software engineering at Motorola, taught mathematics in Botswana, and then obtained a PhD in Robotics from Carnegie Mellon University. At ETH Zürich, Nelson has built an internationally respected research group known for turning fundamental questions into working systems. His laboratory has become a training ground for researchers who value both rigorous science and practical impact, and many of his former students and collaborators now lead their own efforts in academia, industry, and medicine. His work on microrobots has helped move the field from conceptual demonstrations towards clinical relevance. |
Translating Surgical AI Research into Medical Devices | |
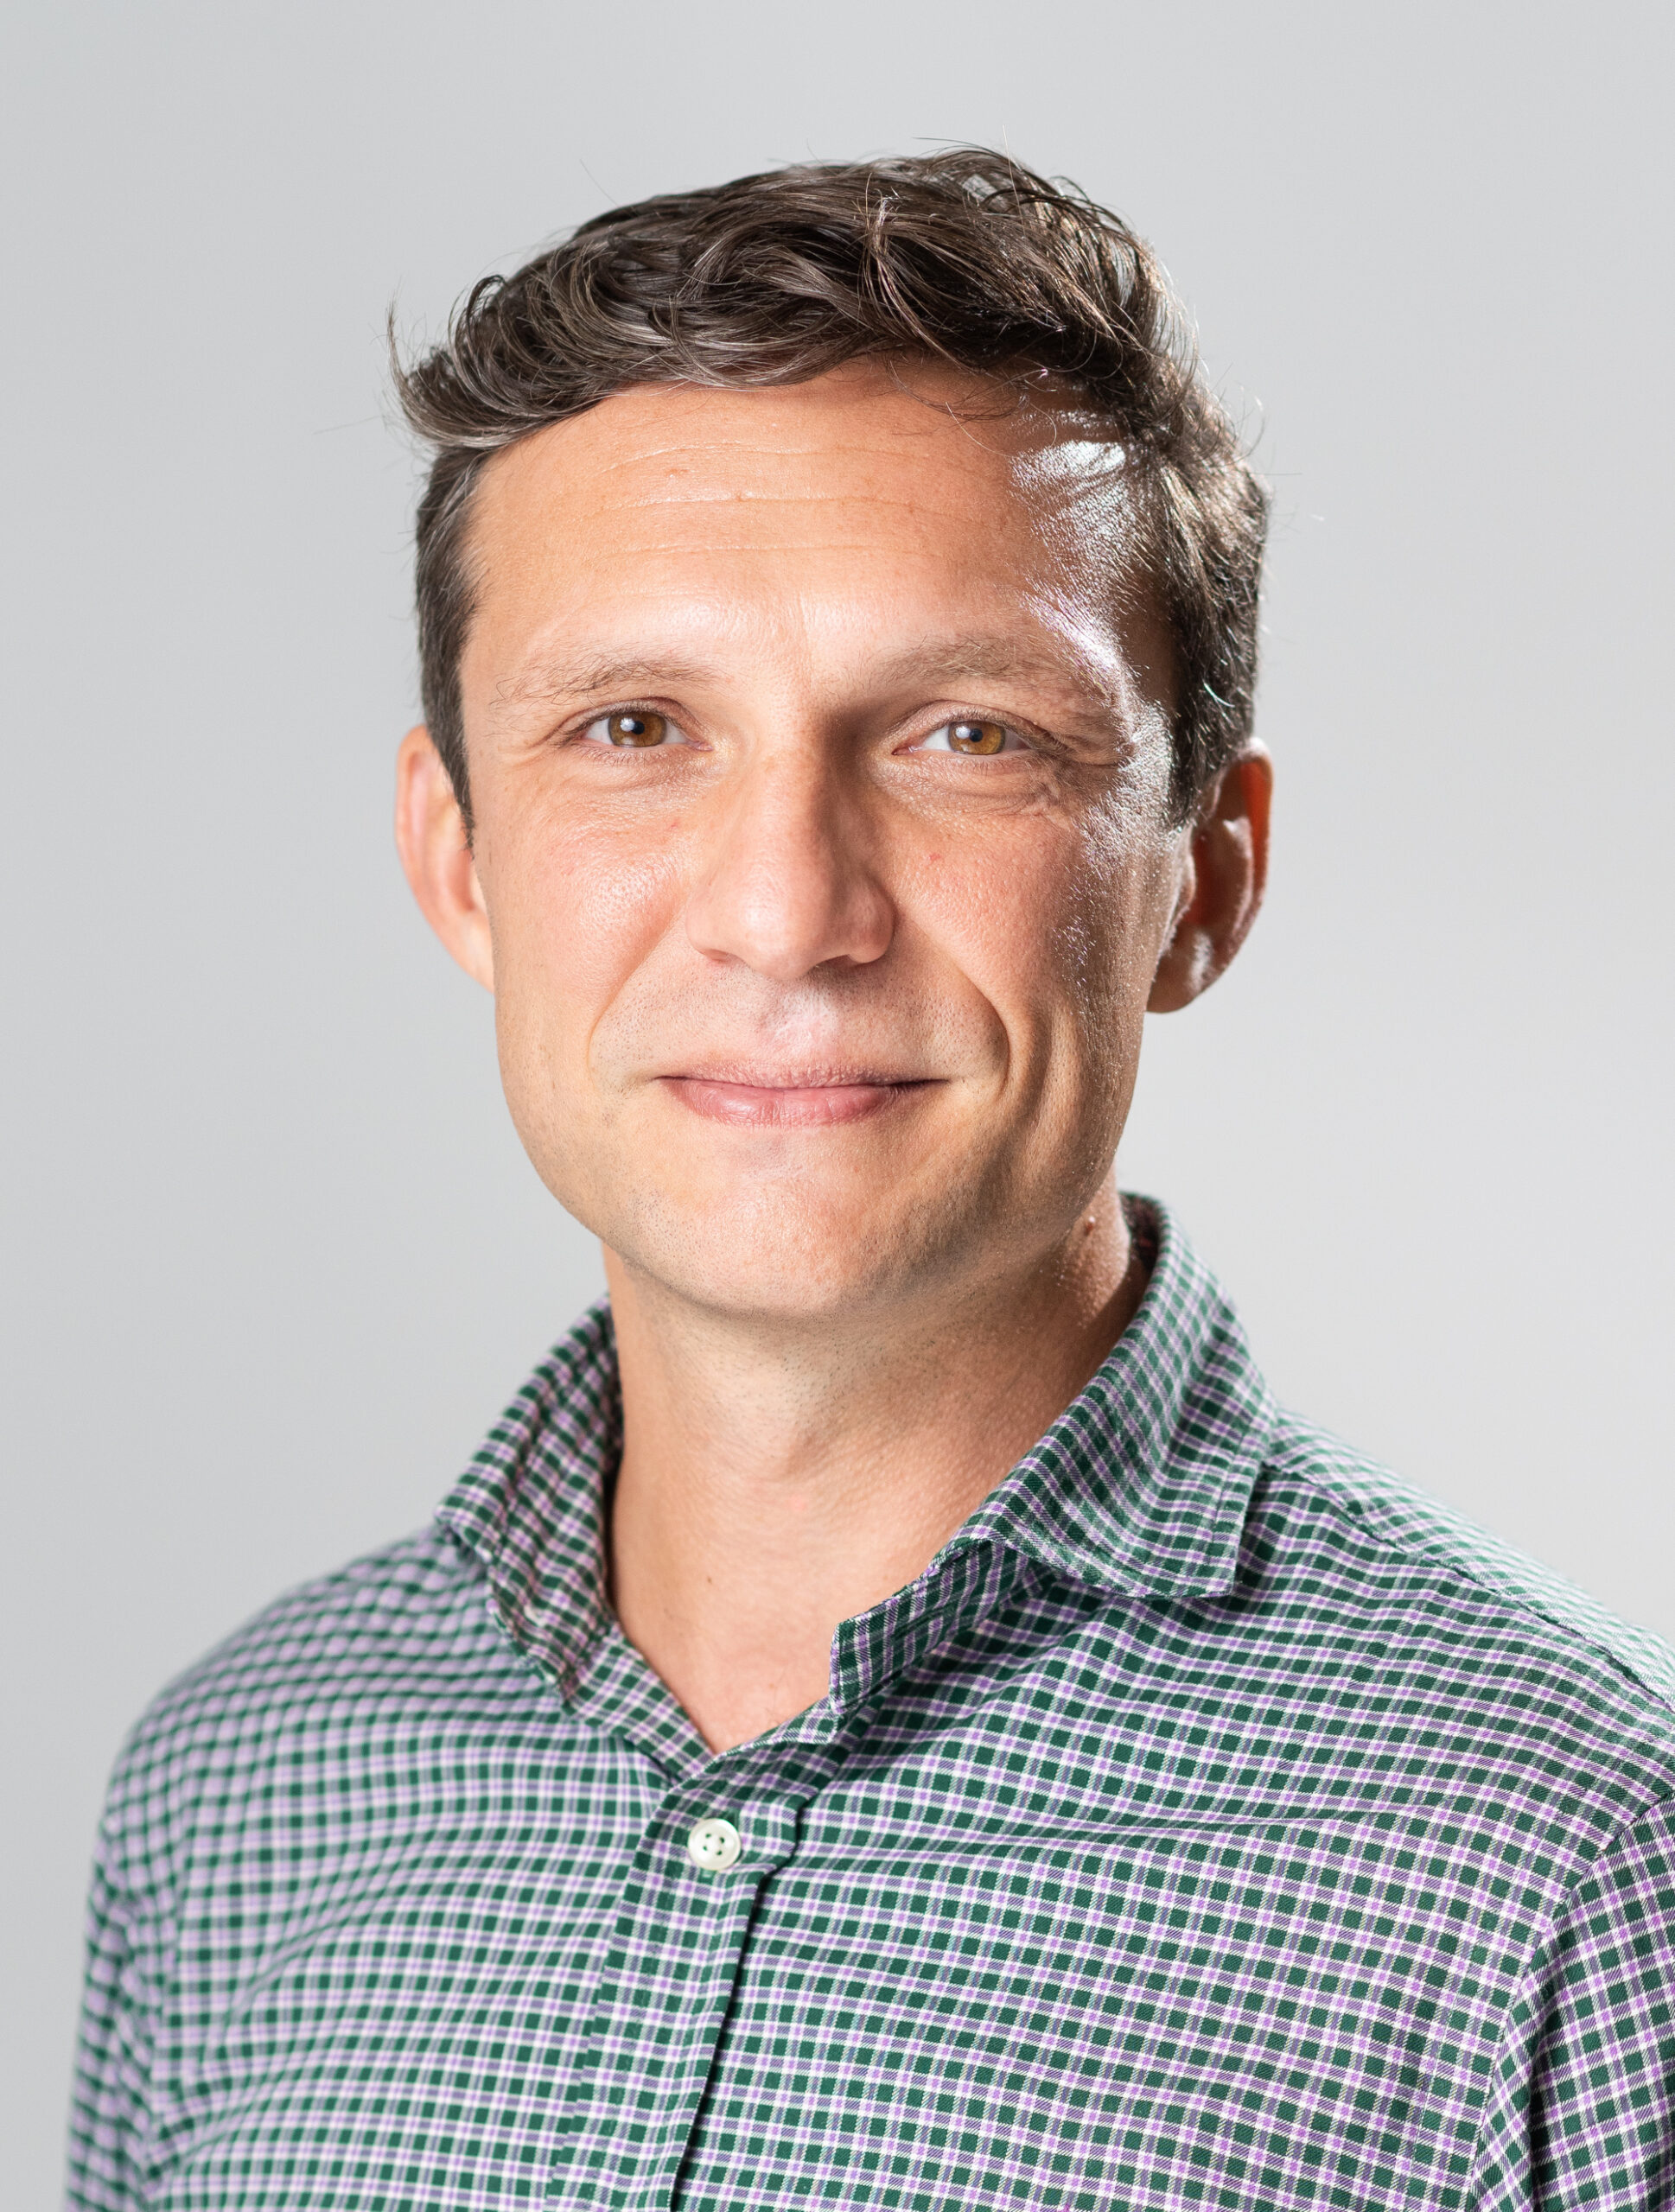 Prof. Dan StoyanovProfessor of Robot Vision, University College London; Chief Scientist for Digital Surgery at Medtronic |
Dan Stoyanov is a Professor at UCL Computer Science and Co-Director of the UCL Hawkes Institute. His research is focused on surgical AI and robotics, with a particular focus on computer vision in surgical endoscopy and minimally invasive surgery. He is a Royal Academy of Engineering Chair in Emerging Technologies, in addition to leading large-scale projects funded by the Wellcome Trust and EPSRC. He is Chief Scientist at Digital Surgery, acquired by Medtronic plc, and co-founder of Odin Vision Ltd, acquired by Olympus, Panda Surgical Ltd, Enacuity Ltd, Helico Technologies Ltd, and Invexo Ltd. He is also a Fellow of the Royal Academy of Engineering, the Academy of Medical Sciences, IEEE, IET, and the MICCAI Society. |
From Surgical Simulation to Active Anatomical Models: Soft Robotics Applied to Surgery | |
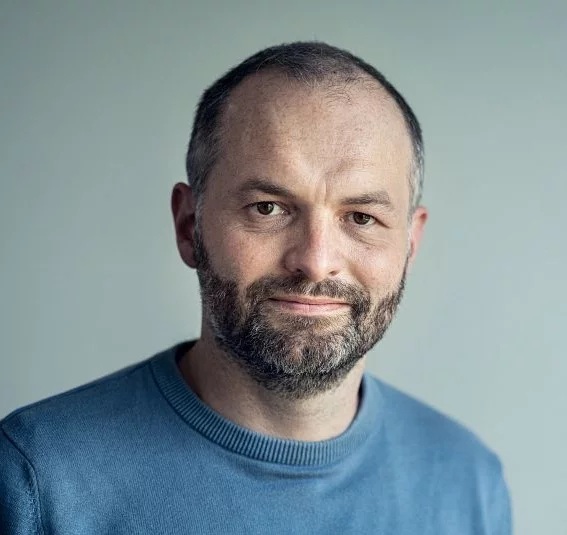 Prof. Christian DuriezResearch Director, Inria; CEO, Compliance Robotics |
Christian Duriez received a PhD in robotics from CEA and the University of Évry, France, in 2004. He was a postdoctoral fellow with the CIMIT SimGroup in Boston, Massachusetts. In 2006, he joined Inria Lille Nord-Europe, where he worked on interactive simulation of deformable objects and haptic rendering, with a focus on surgical simulation. In 2014, he was promoted to Directeur de Recherche and is currently head of the DEFROST team, created in January 2015. In 2018, he was an invited researcher at Stanford University. He contributed to the creation of the open-source SOFA framework and co-founded InSimo in 2013 and Compliance Robotics in 2024. His research interests include soft-robot modelling and control, fast finite-element methods, simulation of contact response, and the use of soft robots for haptics. |
The Application and Challenges of Surgical Robotics in General Surgery | |
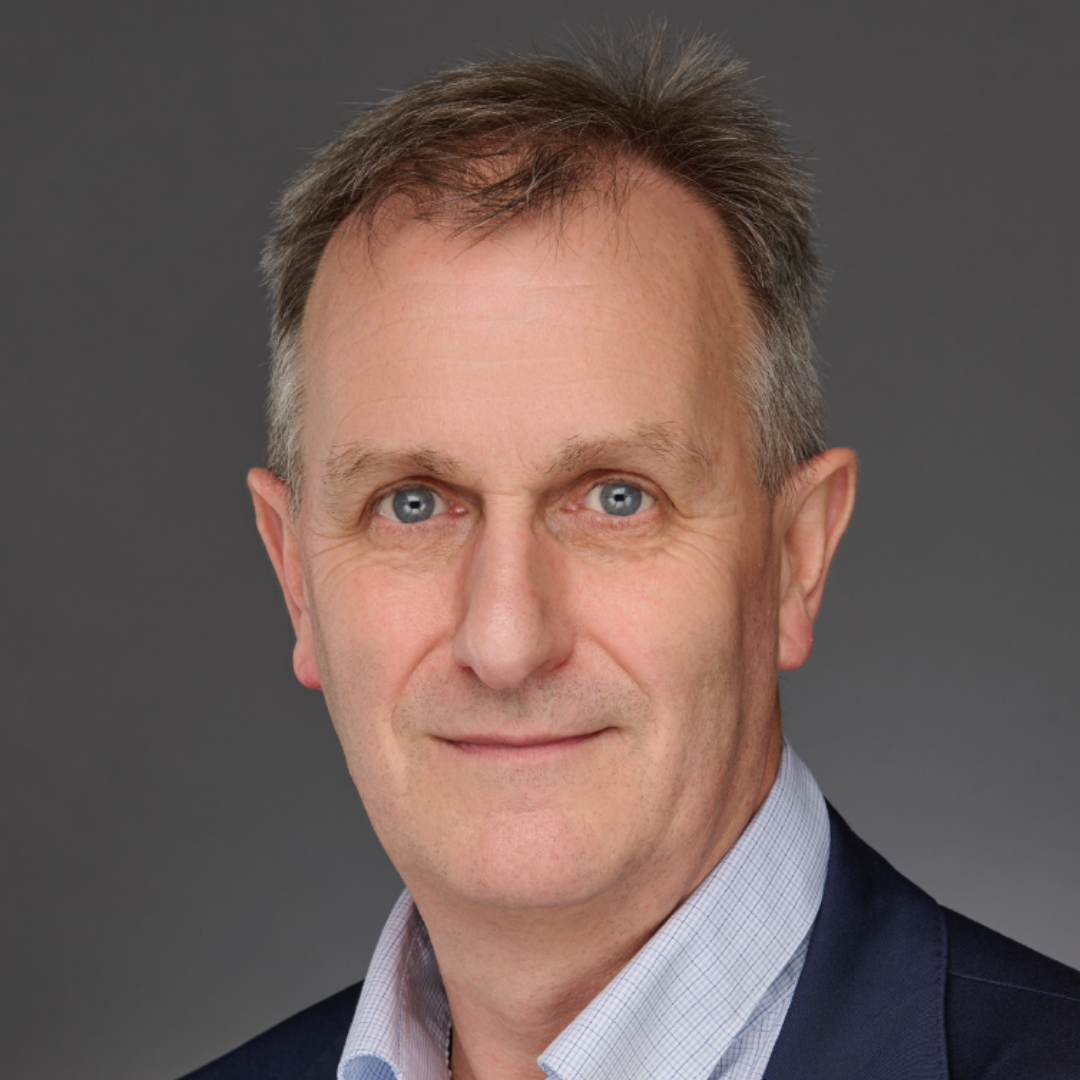 Prof. David JayneProfessor of Surgery, University of Leeds; Honorary Consultant Surgeon, Leeds Teaching Hospitals NHS Trust |
David is Bowel Cancer UK & RCS England Professor of Surgery at the University of Leeds and Honorary Consultant Surgeon at Leeds Teaching Hospitals NHS Trust. His clinical interests include robotic and minimally invasive surgery for colorectal cancer. He is Chief Investigator for several NIHR portfolio clinical trials, including MRC/EME/NIHR ROLARR, HTA/NIHR FIAT, HTA/NIHR SaFaRI, and MRC/EME/NIHR IntAct. He is Director of the Leeds Institute for Medical Research, Clinical Director of the Leeds NIHR HealthTech Research Centre, and Clinical Director for the Leeds RCS England Surgical Trials Centre. He sits on several funding panels, including NIHR Advanced Fellowships, NIHR i4i PDA, and NHSE/SBRI Cancer Innovations Awards. His translational research interests include the development and early-phase evaluation of surgical technologies. |
Honorary Guest Speaker | |
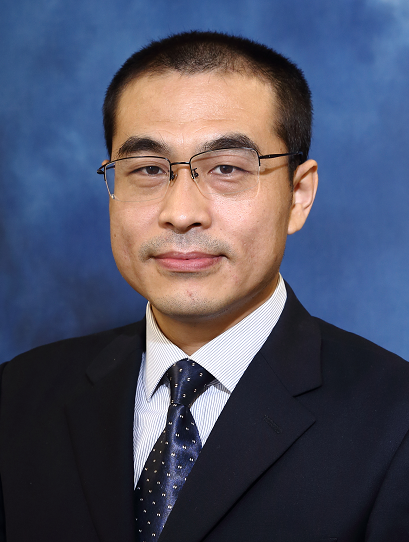 Prof. Hongliang RenProfessor of Electronic Engineering, Chinese University of Hong Kong |
Prof. Hongliang Ren is a Professor in the Department of Electronic Engineering at the Chinese University of Hong Kong, where he received his PhD in 2008. His academic career has included appointments at Johns Hopkins University, Harvard Medical School, leading US children’s hospitals, and the National University of Singapore. His research interests include biorobotics, medical mechatronics, soft continuum robots, intelligent control, soft sensors, and multisensory learning for medical robotics. He is a recipient of the National Science Fund for Distinguished Young Scholars, CUHK Young Researcher Award, NUS Young Investigator Award, IAMBE Early Career Award, and numerous best-paper awards. He is consistently ranked among the world’s top 2% most-cited scientists and has published more than 240 papers, receiving more than 23,000 citations, with an H-index of 77. |
Oral Presentations
Oral Presentations - 1 (Imaging & Visualisation)
Wednesday 16th | 15:00 - 16:00
Chaired by: Emmanuel Vander Poorten and Martina Finocchiaro
| 15:00 - 15:10 | Advanced Anatomical Site Identification in Laryngoscopy: A Prototypical Contrastive Learning Approach for Quality Control Gaia Di Filippo, Aldo Marzullo, Claudio Sampieri, Elisa Bellini, Laura Ruiz Sevilla, Giorgio Peretti, Isabel Vilaseca, Leonardo S. De Mattos and Sara Moccia |
| 15:10 - 15:20 | Online Guidewire Tracking in B-mode Ultrasound: A Kinematic-Gated U-Net Pipeline for Endovascular Robotic Guidance Chen Giladi and Lior Shilon |
| 15:20 - 15:30 | A Synchronized Multimodal Data Collection Framework for AI-Based Autonomous Echocardiography Nicolai Jensen, Tobias Jacobsen, Thiusius R. Savarimuthu, Bruno Oliveira, Preman Kumarathurai, Axel Diederichsen and Viktor Poulsen |
| 15:30 - 15:40 | EndoWrist Joint Configuration Estimation from Monocular Video via Depth Reconstruction and URDF Alignment Andrea Roberti, Riccardo Muradore and Nicola Massignani |
| 15:40 - 15:50 | Optimizing Path Planning for Enhanced Robotic Ultrasound 3D Reconstruction Chiara Bernardini, Kaat Van Assche, Ayoob Davoodi, Marcello Bonfè, Emmanuel Vander Poorten and Gianni Borghesan |
| 15:50 - 16:00 | Autonomous Endoscopic Navigation Based on Real-Time Lumen Segmentation Benjamin Calmé and Pietro Valdastri |
Oral Presentations - 2 (Surgical Robots & Autonomy)
Wednesday 16th | 17:30 - 18:20
Chaired by: Arianna Menciassi and Thiusius Savarimuthu
| 17:30 - 17:40 | Remote Center of Motion Evaluation of a Compliant Joint for Neuroendoscopy Federico Mariano, Elena De Momi, Giovanni Berselli and Leonardo S. Mattos |
| 17:40 - 17:50 | Computationally efficient workspace boundary determination for two-segment continuum robots Joseph Massin and M. Taha Chikhaoui |
| 17:50 - 18:00 | Deformation-Aware Autonomous Circular Cutting in Robot-Assisted Surgery Using MFT-Based Tracking and Online Scissor Pose Planning Yuriko Iyama, Pietro Valdastri and Dominic Jones |
| 18:00 - 18:10 | Delay Compensation for Micro-Macro Bilateral Teleoperation in Robot-Assisted Transoral Laser Microsurgery Ayoob Davoodi, Sukrit Prasarnkleo, Mouloud Ourak, Gianni Borghesan and Emmanuel Vander Poorten |
| 18:10 - 18:20 | Inverse Design Framework for Tissue-Mimicking Phantoms: Applications in Computer and Robot-Assisted Surgery Abu Bakar Dawood, Zhenyu Zhang, Dalia Osman, Cem Suulker, Arsen Abdulali, Martin Angelmahr and Kaspar Althoefer |
Oral Presentations - 3 (Human Factors & Surgical Performance)
Thursday 17th | 09:00 - 10:00
Chaired by: Ilana Nisky and Leonardo De Mattos
| 09:00 - 09:10 | Bimanual Structure in Surgical Preparation Eugenia Akpo, Nicholas Raison, Christos Bergeles and Letizia Gionfrida |
| 09:10 - 09:20 | Evaluation of Foundation Models for predicting visual outcomes after Epiretinal Membrane Surgery Giulia Galvan, Ivo De Clerk, Mouloud Ourak, Elena De Momi and Emmanuel Vander Poorten |
| 09:20 - 09:30 | Vision-Based Hand-Motion Analysis for Ergonomic Assessment in Emulated Robot-Assisted Partial Nephrectomy Deborah Cattafesta, Elisa Iovene, Mariachiara Di Cosmo, Federica Ferraguti and Sara Moccia |
| 09:30 - 09:40 | Towards Sensor-Free Surgical Skill Assessment Using Video-Based Multimodal Learning Ali Osman and Duygu Sarikaya |
| 09:40 - 09:50 | Real-Time AI Generative Feedback for full-lung bronchoscopy instruction Chuan Tian, Yu Hao, Haolin Jiang, Bruno Oliveira, Lars Konge, Kristoffer Cold and Zhuoqi Cheng |
| 09:50 - 10:00 | Real-Time Instance Segmentation in the Operating Room with Selective Refinement of Rare Surgical Instruments Rossella Damiano, Elena De Momi, Alberto Cesare Luigi Redaelli, Aldo Marzullo and Alice Ivanaj |
Oral Presentations - 4 (Sensing & Control 1)
Thursday 17th | 15:30 - 16:30
Chaired by: Di Wu and Nicola Piccinelli
| 15:30 - 15:40 | GelFlip: A Flip-Open Visual-Tactile Palpation Probe for Dual-Mode Sensing in Minimally Invasive Surgery Chuang Lu, Ziting Liang, Tianchi Chen, Yuyu Cai, Danail Stoyanov and Agostino Stilli |
| 15:40 - 15:50 | Human-Robot Shared Control for Markerless Pedicle Subtraction Osteotomy Procedure Ingrid Tombini and Elena De Momi |
| 15:50 - 16:00 | Electrical Impedance Tomography in Constrained Endoscopy Applications Chiara Falagario, Zhuoqi Cheng, Elena De Momi and Leonardo De Mattos |
| 16:00 - 16:10 | Deep Learning-Based contact detection for Robot-Assisted retinal surgery using microscope and OCT imaging Giulia Galvan, Ivo De Clerck, Joy Haegemans, Mouloud Ourak and Emmanuel Vander Poorten |
| 16:10 - 16:20 | Weakly Supervised Depth Estimation and Control of a Micropipette Huanyu Tian, Martin Huber, Lingyun Zeng, Zhe Han, Wayne Bennett, Giuseppe Silvestri, Gerardo Mendizabal-Ruiz, Tom Vercauteren, Alejandro Chavez-Badiola and Christos Bergeles |
| 16:20 - 16:30 | A Tactile Sensing Array for Force Quantification in Robot Assisted Surgery Charles DeLorey, Michael Brockdorff, Adam Metcalf, Benjamin Calmé, Pietro Valdastri and Dominic Jones |
Oral Presentations - 5 (Magnetics)
Thursday 17th | 17:00 - 18:30
Chaired by: Veronica Iacovacci and Venkatasubramanian Kalpathy Venkiteswaran
| 17:00 - 17:10 | An electromagnetic catheter for on-demand release and in-situ manipulation of magnetic therapeutic cargoes Riccardo Panizzolo, Tamerlan Srymbetov, Arianna Menciassi and Veronica Iacovacci |
| 17:10 - 17:20 | Selectively Triggerable Biopsy Capsule via Multi-stage Magnetic Torsion Springs Simon Frieler, Jean-Paul P M de Vries, Sarthak Misra, Eric Diller and Venkatasubramanian Kalpathy Venkiteswaran |
| 17:20 - 17:30 | Volumetric Magnetic Model and Polar-Coordinate Inverse Solver for Model-Based Control of a Magnetically Actuated Capsule Robot Vito Romanello, Tamerlan Srymbetov, Arianna Menciassi and Veronica Iacovacci |
| 17:30 - 17:40 | Endoscopic Deployment of Magnetic Soft Continuum Robots for Targeted Gastrointestinal Therapy Alistair Bacchetti, Alexander Brown, Benjamin Calmé, Pietro Valdastri and James H. Chandler |
| 17:40 - 17:50 | Forward-Model-Based Anomaly Detection for Magnetic Localization Systems İsmail Şahin, Cengizhan Öztürk and Otar Akanyeti |
| 17:50 - 18:00 | Magnetic–Fluidic Soft Robotic Catheter Tip for Enhanced Access in Superior Mesenteric Artery Aneurysm Intervention Muhammad Abdullah Khalid, Pietro Valdastri and James H. Chandler |
| 18:00 - 18:10 | A deployable, magnetically driven soft robotic platform for laparoscopic surgery: modeling, design and preliminary validation works Matteo Bernabei, Lorenzo Mocellin, Matteo Cianchetti, Arianna Menciassi, Cesare Stefanini and Gastone Ciuti |
| 18:10 - 18:20 | AI Generated Synthetic Data for Accelerating the Development of Data-Driven Magnetic Localization Models İsmail Şahin, Cengizhan Öztürk and Otar Akanyeti |
| 18:20 - 18:30 | Bi-directional Magnetic Vine Robot for Enhanced Endoscopic Navigation Alexander Brown, Alistair Bacchetti, Benjamin Calmé, Joshua Davy, Sukjun Kim, Tania K Morimoto, James H. Chandler and Pietro Valdastri |
Oral Presentations - 6 (Novel Devices)
Friday 18th | 09:00 - 10:10
Chaired by: Agostino Stilli and Lin Cao
| 09:00 - 09:10 | A Low-Cost Smartphone-Based Diabetic Retinopathy Screening System Integrating AI Classification for Resource-Limited Settings Ricardo Harrison, Gerardo Galindo, Nikita Greenidge, Sasha-Gay Wright and Pietro Valdastri |
| 09:10 - 09:20 | Reconfigurable Magnetic Catheter Delivery with a Pressure-Lockable Hybrid Continuum Robot Burak Ozdemir, Muhammad Abdullah Khalid, Benjamin Calmé, Pietro Valdastri and James H. Chandler |
| 09:20 - 09:30 | A Miniaturized Everting Robot with a Large Working Channel for Ureteroscopy Using Twisted Tail Pushing Juliana Dreyer, Cédric Girerd, Cécile Manceau, Nicolas Abdo and Nabil Zemiti |
| 09:30 - 09:40 | Towards Miniature Soft Vine Robots for Ultrasound Imaging of the Uterine Cervix Andrea Libertad Yanez Trujillo, Nikita Greenidge, Benjamin Calmé, Joshua Davy, Pietro Valdastri, James H. Chandler, Virginia Pensabene and James Avery |
| 09:40 - 09:50 | Improved Passive Navigation in Soft Growing Eversion Robots Through Embodied Intelligence via Constrictive Bands Cem Suulker, Muhie Al Haimus, Thomas Mack, Mohammad Sheikh Sofla, Neri Niccolo Dei, Reza Kashef, S.M.Hadi Sadati and Kaspar Althoefer |
| 09:50 - 10:00 | Origami Polyimide Sleeves for Protection of Variable Length Soft Endoscopic Actuators Thomas Dean, Benjamin Calmé, Burak Ozdemir, Bao Nguyen, Pietro Valdastri and James H. Chandler |
| 10:00 - 10:10 | Towards Automated Fabrication of Soft Robotic Endoscope Tips for Affordable Gastroscopy Alexander Brown, Pietro Valdastri and James H. Chandler |
Oral Presentations - 7 (Sensing & Control 2)
Friday 18th | 16:00 - 17:00
Chaired by: Zhuoqi Cheng and Yao Zhang
| 16:00 - 16:10 | Towards a Sensorised Balloon for Lumen and Polyp Detection using Electrical Impedance Tomography Jackson Williams, Pietro Valdastri, James Avery and James H. Chandler |
| 16:10 - 16:20 | Proximal Sensing of Instrument Rotation in Endovascular Procedures Maria Lopes, Wim-Alexander Beckers, Emmanuel Vander Poorten and Beatriz Barata |
| 16:20 - 16:30 | Towards Combined Diffuse Reflectance and Electrical Impedance Spectroscopy for Colorectal Tissue Characterisation Lukas Wachtel, Nilanjan Mandal, Jackson Williams, Andrea Libertad Yanez Trujillo, James Avery and Alexander J Thompson |
| 16:30 - 16:40 | Experimental Characterization of NURD in OCT Catheters Under Curvature and Rotational Speed Variations Zeno Pogacnik, Giovanni Battista Regazzo, Beatriz Farola Barata, Daniel Corona Oliveira Costa, Emmanuel Vander Poorten and Oscar Caravaca-Mora |
| 16:40 - 16:50 | Shape control of a concentric tube continuum robot for surface ECoG brain implant insertion in a highly constrained environment Ambroise Ulrich, Taha Chikhaoui, Blaise Yvert and Edwige Bano |
| 16:50 - 17:00 | Magnetic Force Sensing in Ophthalmic Surgical Robot Forceps: Design, Integration, and Validation Charles DeLorey, Benjamin Jackson, Mojtaba Esfandiari, Pietro Valdastri, Iulian Iordachita and Dominic Jones |
Poster Pitches
Poster Pitches 1
Thursday 17th | 10:00 - 11:06
Honorary Guest Speaker: Prof. Hongliang Ren, 10:00 - 10:20. Poster pitches begin at 10:20.
| 10:20 - 10:22 | A Concentric Tube Catheter, Actuated and Imaged via MRI Peter Lloyd, Yael L. May, Jurgen E. Schneider and Pietro Valdastri |
| 10:22 - 10:24 | Characterization of Robotic Needle Insertion for Automatic Biopsy Sampling of Dynamic Multilayer Polymeric Lung Phantoms Maria Diaz, Gerardo Ramirez and Jorge Chairez |
| 10:24 - 10:26 | Teleoperation of a Six-DOF Parallel Manipulator for Spinal Decompression Surgery - Evaluation via Eggshell Grinding Experiments Keng-Hua Yeh, Shih-Hsin Chen and Hsuan-Yu Chen |
| 10:26 - 10:28 | Compliance-Based Sensor Placement for Force Sensing on a Sensorized Prostate Phantom Sizhe Tian, Yinoussa Adagolodjo and Jeremie Dequidt |
| 10:28 - 10:30 | Optimization-based compliance control for surgical continuum robots Mattia Reina, Benoit Rosa and Hassan Omran |
| 10:30 - 10:32 | A Novel 2-DOF Continuous Hydraulic Motor for MR Intervention Robotics Xinxin Li and Tse Zion |
| 10:32 - 10:34 | Elastic Loop Transfer Task: Bimanual Manipulation of Elastic Objects in Robot-Assisted Surgery Shani Arusi, Uri Netz and Ilana Nisky |
| 10:34 - 10:36 | A soft endoscopic robot for minimally invasive in situ bioprinting Ruben Martin Rodriguez, Calvin Rüegg, Lorin Fasel, Nicolas Gerig, Valentina Basoli, Georg Rauter and Florian Thieringer |
| 10:36 - 10:38 | AR Visualization of Workspace Overlap for Collision Prevention in Robot-Assisted Surgery with Hugo™ RAS Jonas Jakobi, Lukas Freiling and Do Yeon Kim |
| 10:38 - 10:40 | A Physics-Informed Neural Network for FBG-Based Force Vector and Location Identification along a Flexible Catheter Xinran Liu, Emmanuel Vander Poorten, Mouloud Ourak and Johan Bennett |
| 10:40 - 10:42 | Optimising Prostate Cancer Diagnosis with AI-Assisted Surface-Based Ultrasound-Derived Prostate-Specific Antigen Density Rory Bennett, Tristan Barrett, Vincent Gnanapragasam and Zion Tse |
| 10:42 - 10:44 | Markerless Real-Time Target Tracking and Pose Estimation for Robot-Assisted Terahertz Imaging of Human Skin Xiangyu Guo, Junlei Hu, Agrima Agarwal, Anubhav Dogra, Pietro Valdastri and Emma Pickwell-MacPherson |
| 10:44 - 10:46 | Applying AI techniques to EMG sensor data to predict localized muscle fatigue in RAS training: Standing and sitting postural approach Daniel Caballero, Alfonso Fernández-Montero, Juan A. Sánchez-Margallo and Francisco M. Sánchez-Margallo |
| 10:46 - 10:48 | A Transparent Simulation-Centered Co-Robotic Platform for Human-Supervised Spinal Surgery Daniel Shabanian, Pedro Machado, Kartikeya Walia and Philip Breedon |
| 10:48 - 10:50 | Development of a Pancreatic Phantom for Surgical Training Arianna Callera and Francesco De Gaetano |
| 10:50 - 10:52 | Intuitive Robot-Assisted Drilling with Haptic Feedback and Multi-Layer Safety Constraints Roman Leonov, Johannes Hölker, Do Yeon Kim, Dennis Kundrat and Jan E H Wolff |
| 10:52 - 10:54 | Kinematic considerations in laparoscopic surgical robots. Impact on usability Josep Amat, Alicia Casals and Narcís Sayols |
| 10:54 - 10:56 | Physics-Guided Residual Modeling for Transient Prediction in Pneumatic Soft Continuum Robots Wei Qiyu, Junbao Liu and Manish Chauhan |
| 10:56 - 10:58 | Quantitative Magnetic Centralisation for Millirobot MRI Localisation Yael L. May, Peter Lloyd, James H. Chandler, Pietro Valdastri and Jurgen E. Schneider |
| 10:58 - 11:00 | 2 Step Constraint Resolution With Regularization For Robotic Endoscopes With Environment Contacts Maël Bianchi, Benoit Rosa and Hadrien Courtecuisse |
| 11:00 - 11:02 | Deep Learning 3D Surgical Tool Pose Estimation using Geometry-Aware Correction Alexandros Dimitriadis, George Moustris and Costas Tzafestas |
| 11:02 - 11:04 | Exploiting Kinematic Redundancy for Active Stiffness Modulation of Continuum Concentric Push-Pull Robots Azad Artinian, Taha Chikhaoui and Benoit Rosa |
| 11:04 - 11:06 | A SOFA-Based Virtual Reality Simulator for Vascular Procedures Integrated with the da Vinci Research Kit Giulia Gamberini, Carlo Lodin, Selene Tognarelli and Arianna Menciassi |
Poster Pitches 2
Friday 18th | 10:10 - 10:54
| 10:10 - 10:12 | Magnetic Actuation of Vine Robots for Tortuous Surgical Navigations Joshua Davy, Nikita Greenidge, Nam Gyun Kim, Thomas Dean, Sukjun Kim, Shinwoo Park, Benjamin Calmé, Peter Lloyd, James H. Chandler, Jee Hwan Ryu, Tania K Morimoto and Pietro Valdastri |
| 10:12 - 10:14 | Multi-fidelity model for thermal lesion prediction in robotic Ultrasound-Guided High-Intensity Focused Ultrasound surgery Francesca Parrotta, Giulia Gamberini, Selene Tognarelli, Giovanni Stabile and Arianna Menciassi |
| 10:14 - 10:16 | Vision-Based Surgical Skill Assessment for Ring Transfer Tasks Using YOLO Segmentation Andrea Roberti, Sofia De Sanctis and Riccardo Muradore |
| 10:16 - 10:18 | Advanced 5G Standalone Infrastructure for Remote Surgical Robotics: Design and Validation of the OSLO Platform Juan A. Sánchez-Margallo, Carlos Argent Masa and Francisco M. Sánchez-Margallo |
| 10:18 - 10:20 | Evaluating localized muscle fatigue during suturing tasks in MIS surgical training Alfonso Fernández-Montero, Daniel Caballero, Manuel J. Pérez-Salazar, Juan A. Sánchez-Margallo and Francisco M. Sánchez-Margallo |
| 10:20 - 10:22 | Preliminary Characterisation of Angular Overshoot and Oscillation in a Pneumatic Soft Continuum Robot Qiyu Wei, Haorui Sun and Manish Chauhan |
| 10:22 - 10:24 | A Low-Power Multi-Sensor Navigation Architecture for Spatial Mapping of Endoscopic Capsules Sahil Anchal, Sean Coombes, Daragh Crowley, Eoin Higgins, Herman Alexander Jaeger and Pádraig Cantillon-Murphy |
| 10:24 - 10:26 | Constraint Programming for Robotic Arm–Assisted Delivery of Ultrasound-Guided High-Intensity Focused Ultrasound (USgHIFU) Manisha Waterston, Lewis Howell, Bailey Andrew, James H. Chandler, Tze Min Wah and James McLaughlan |
| 10:26 - 10:28 | Dense Estimation of Retinal Tectonics via Radial Basis Function Interpolation Tommaso Delucchi, Nicola Piccinelli, Andrea Roberti, Riccardo Mondin, Marco Pellegrini and Riccardo Muradore |
| 10:28 - 10:30 | A Multimodal Laparoscopic Training Dataset for Automated Surgical Skill Assessment in Low-Resource Settings Omar Choudhry, Sharib Ali, Chandra Shekhar Biyani and Dominic Jones |
| 10:30 - 10:32 | Benchmarking object detectors for naso-endoscopic anatomical features Manuel Rocha, Willem Jansen, Cláudia Rocha, Armando Sousa, Maarten van Alphen, Michiel van den Brekel and Françoise Siepel |
| 10:32 - 10:34 | A Pre-Experimental Scan-Planning Simulator for Hexapod-Mounted On-Chip Terahertz Sensing Nikita Greenidge, Connor D W Mosley, Josh P R Nixon, Cunningham John E. and Pietro Valdastri |
| 10:34 - 10:36 | Trackerless Freehand Ultrasound 3D Reconstruction in Orthopedic Surgery Jinghao Fei, Ruixuan Li, Carlos Rodriguez-Guerrero and Emmanuel Vander Poorten |
| 10:36 - 10:38 | Electrical Bio-Impedance Sensing on 2-Layered Tissue Model Marianne Viola Petersen, Thiusius R. Savarimuthu and Zhuoqi Cheng |
| 10:38 - 10:40 | Feasibility of Machine Learning-Based Tissue Discrimination Using Electrical Bioimpedance Sensing Yao Zhang, Anas El Hila, Teshome Getu Mhret, Mouloud Ourak and Emmanuel Vander Poorten |
| 10:40 - 10:42 | Evaluating Kinematic Tracking Stability and Load-Dependent Error in the da Vinci Research Kit (dVRK) Christos Toilos, Evangelos Mazomenos and Laurent Mennillo |
| 10:42 - 10:44 | Pneumatically Actuated MRI-Compatible Robot for Spinal Needle Procedures Yuxuan Qi, Aminul Ahmed, Christos Bergeles and Zion Tse |
| 10:44 - 10:46 | Vibroacoustic-Based Bone Density Differentiation During Robotic Drilling Marthe Van den Bogaert, Maikel Timmermans, Kaat Van Assche, Ayoob Davoodi, Wim Desmet, Emmanuel Vander Poorten and Kathleen Denis |
| 10:46 - 10:48 | Design of a Surgical Gripper with Tunable Constant Gripping Force for Safe Tissue Handling Haopeng Lu, Zhuoqi Cheng, Thiusius R. Savarimuthu and Di Wu |
| 10:48 - 10:50 | An Open-Source Environment for Autonomous Robotic Colonoscopy Navigation Guanglin Ji, Martina Finocchiaro, Kenny Erleben and Hang Yin |
| 10:50 - 10:52 | Intracardiac Soft Robotic Design for CPR Application Zhihao Ma, Linxiaohai Ning, Xinxin Li, Tim Harris and Tse Zion |
| 10:52 - 10:54 | A Re-positionable and Axially Re-orientable Pivot-Joint Steering Mechanism for Tip-Everting Soft Growing Robots Tianchen Ji, Diyang Wu, Zheyuan Bi and Lin Cao |
Presentation Guidelines
Oral Presentations
- Each oral presentation is allocated 10 minutes: 8 minutes for the presentation and 2 minutes for Q&A.
- Slides must be submitted in advance. Instructions will be sent by email.
- Please arrive at the auditorium 5 minutes before your session begins to ensure everything is ready.
- Assistance will be provided by a member of the local team.
- We provide a oral presentation/poster pitch template in PowerPoint (.pptx), but participants are free to use their own design.
Poster Pitches
- Each poster pitch is limited to 1 minute and should be accompanied by 1 slide.
- The slide must be submitted in advance. Instructions will be sent by email.
- We provide a oral presentation/poster pitch template in PowerPoint (.pptx), but participants are free to use their own design.
Posters
- Posters should be prepared in A0 portrait format (w:841mm x h:1189mm).
- We provide poster templates in both PowerPoint (.pptx) and LaTeX, but participants are free to use their own design.
- We will provide numbered poster boards and ask individuals to mount their posters as soon as possible after registration.
- Presenters must be next to their posters during the coffee break that follow their poster pitch session.